Probing H-RTK GPS
Note
For cabling connection:
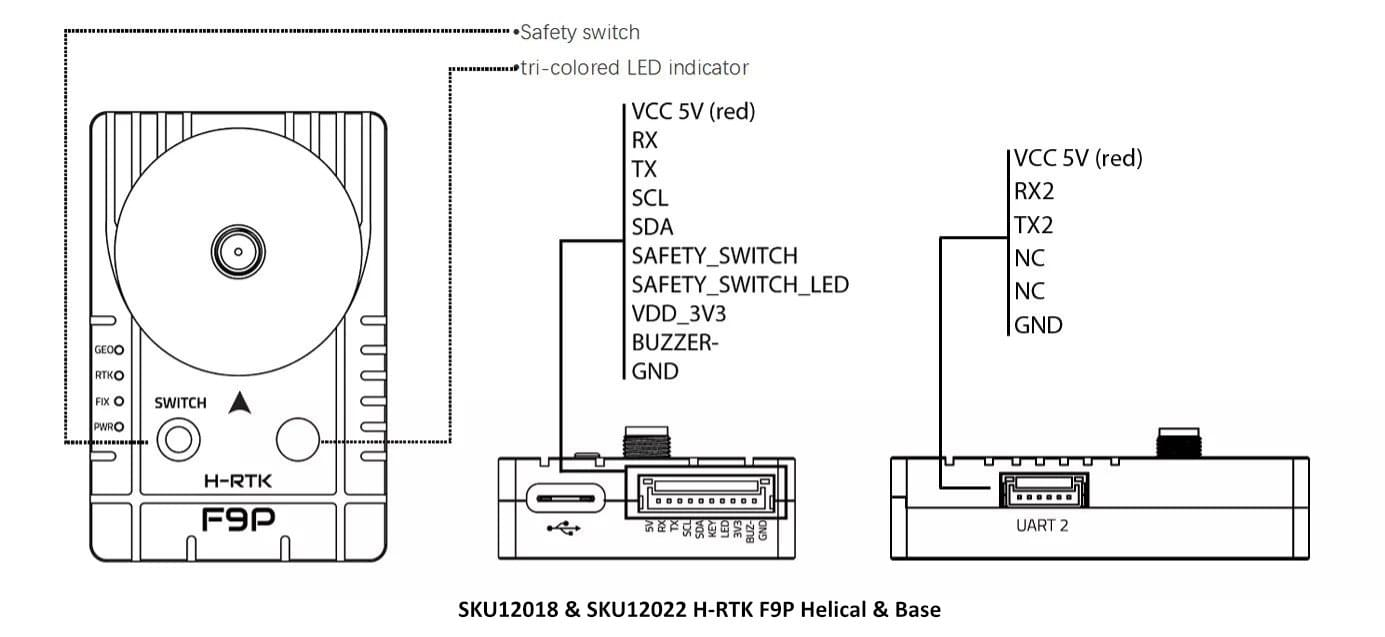
Checking GPS stream in Serial
import serial
import time

port_name = '/dev/ttyTHS1'
baud_rates = [9600, 38400, 57600, 115200, 230400, 460800]

print(f"Scanning {port_name}...")


for baud in baud_rates:
    print(f"\n--- Testing Baud Rate: {baud} ---")
    try:
        with serial.Serial(port_name, baud, timeout=2) as ser:
            # Clear buffer
            ser.reset_input_buffer()

            # Read a chunk of data
            data = ser.read(100)

            if not data:
                print("No data received.")
                continue

            # Check for NMEA (starts with $)
            try:
                text_data = data.decode('ascii', errors='ignore')
                if '$G' in text_data:
                    print(f"SUCCESS! Found NMEA data at {baud}.")
                    print(f"Sample: {text_data[:50]}")
                    break
            except:
                pass

            # Check for UBX (starts with 0xB5 0x62)
            if b'\xb5\x62' in data:
                print(f"SUCCESS! Found UBX Binary data at {baud}.")
                print("This is binary data (not human readable text).")
                print(f"Hex sample: {data[:20].hex()}")
                break

            print(f"Data received but unrecognized (likely wrong baud): {data[:20]}")

    except Exception as e:
        print(f"Error opening port: {e}")
Checking Magnetometer stream in I2C
import smbus
import time

# Configuration
BUS_NUM = 7          # The bus you found with i2cdetect
DEVICE_ADDR = 0x0E   # The address of the IST8310
REG_CNTL1 = 0x0A     # Control Register 1
REG_DATA = 0x03      # Starting Data Register (X_Low)
MODE_SINGLE = 0x01   # Value to trigger a single measurement

def read_magnetometer():
    try:
        bus = smbus.SMBus(BUS_NUM)

        print(f"Reading IST8310 on Bus {BUS_NUM}...")

        while True:
            # 1. Trigger a single measurement
            # IST8310 often needs to be "poked" for every reading
            bus.write_byte_data(DEVICE_ADDR, REG_CNTL1, MODE_SINGLE)

            # 2. Wait for measurement (approx 6ms usually sufficient)
            time.sleep(0.02)

            # 3. Read 6 bytes of data: X_L, X_H, Y_L, Y_H, Z_L, Z_H
            data = bus.read_i2c_block_data(DEVICE_ADDR, REG_DATA, 6)

            # 4. Convert 2's Complement (combining Low and High bytes)
            x = data[1] * 256 + data[0]
            if x >= 32768: x -= 65536

            y = data[3] * 256 + data[2]
            if y >= 32768: y -= 65536

            z = data[5] * 256 + data[4]
            if z >= 32768: z -= 65536

            # Print raw values (roughly corresponds to microTesla uT)
            print(f"Mag Raw: X={x:5d}  Y={y:5d}  Z={z:5d}")

            time.sleep(0.1)

    except Exception as e:
        print(f"Error: {e}")

if __name__ == "__main__":
    read_magnetometer()